Stereo Workflow
Stereo (HMC) is the highest-fidelity job type — the depth-constrained solve resolves facial geometry that monocular footage cannot. In exchange each take needs two parent assets for its actor first: a camera calibration and a prepared MetaHuman Identity. The queue produces both and chains them for you.
Pipeline stages
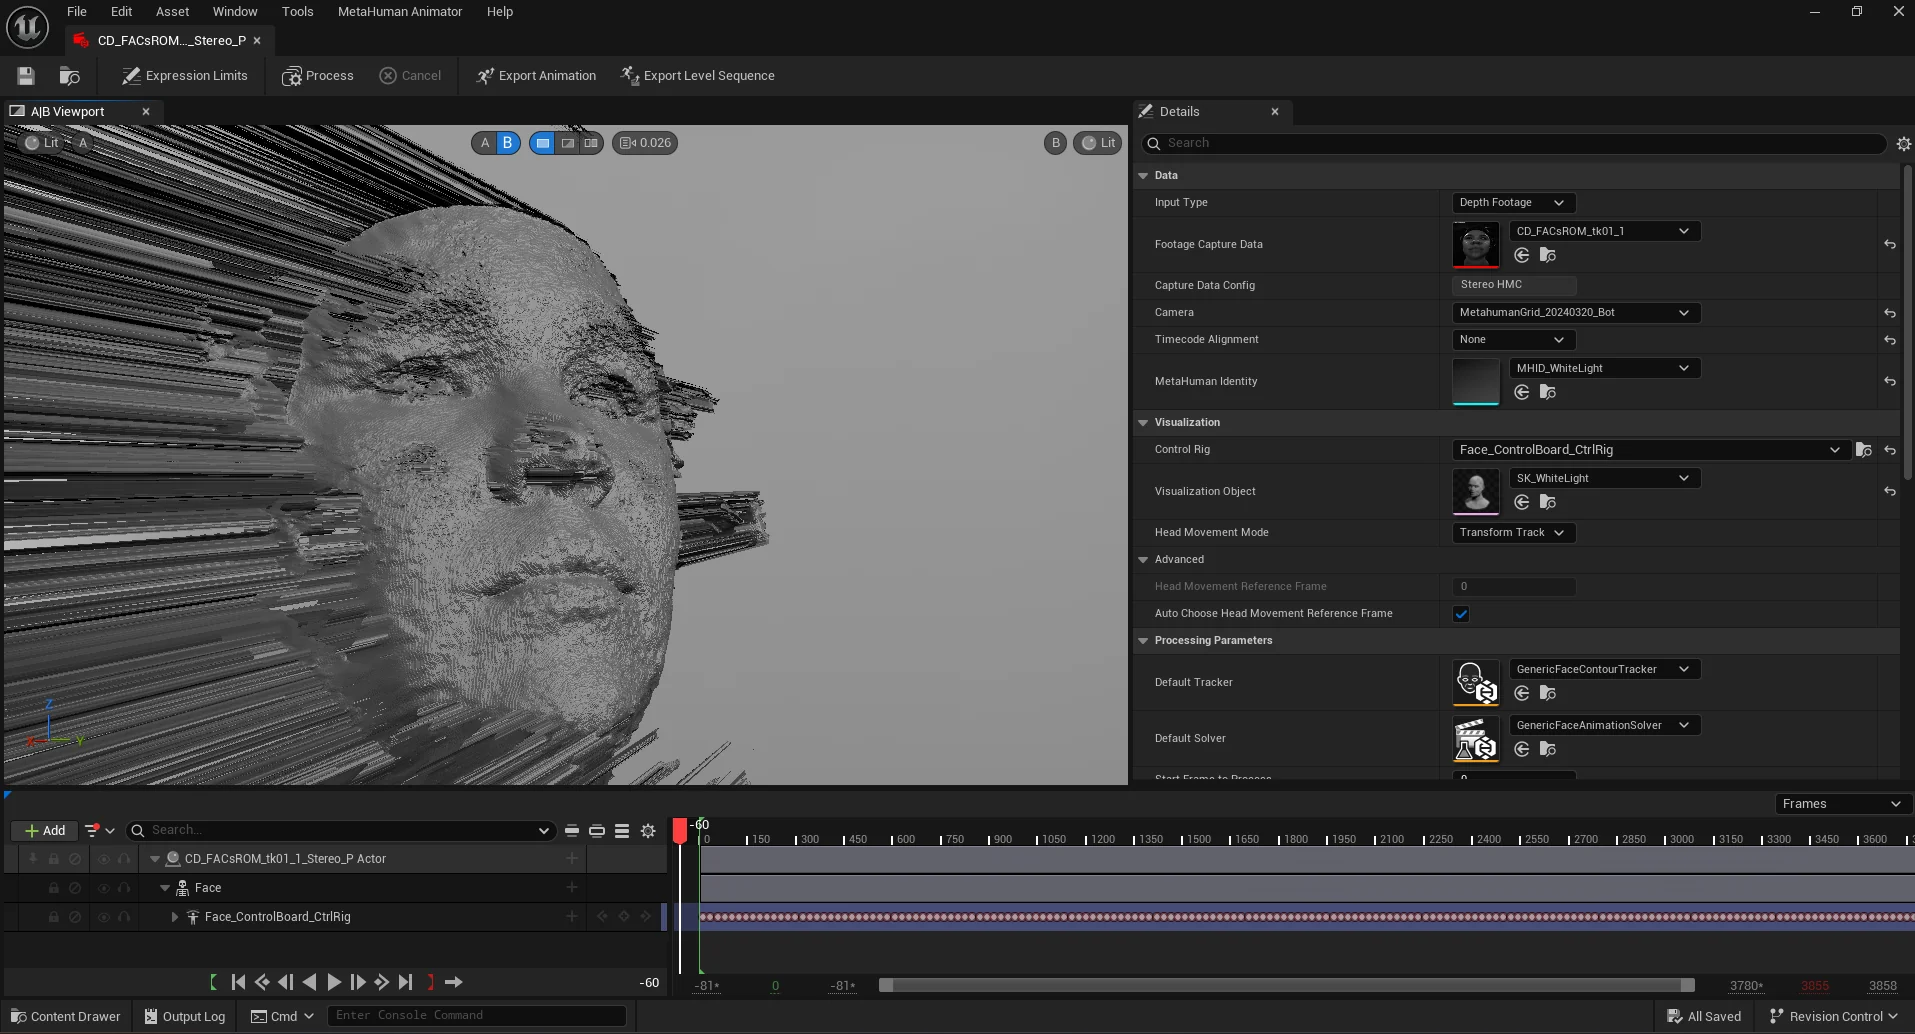
Required assets
UFootageCaptureData Must reference both camera image sequences UMetaHumanIdentity Auto-discovered under the actor folder; built by an Identity Create job UCameraCalibration Required for depth generation; auto-discovered, or built by a Calibration job The parent chain
Stereo is a family of three job types in a strict dependency order. The first two exist only to produce the assets the third consumes:
CameraCalibration from a checkerboard take, linked to the take and discoverable by the actor's other takes. - MetaHumanIdentity (MHID_<Actor>), built from an identity take using the calibration. Needs the calibration (for depth). Runs in an interactive editor (cloud AutoRig login). Performance asset + face AnimSequence — a depth-constrained solve. Needs both the calibration and the prepared identity for its actor. Queue in any order
Execution ignores row order: the batch runs CalibrateStereo first, Identity Create
second, everything else third, so prerequisites exist by the time a take preflights.
The queue is strictly serial (Epic's single-performance lock), and takes classify by name —
grid / calib tokens become CalibrateStereo, identity /
dna become Identity Create. Drop a whole actor folder in at once and let the tiers
sort themselves out.
Imports/Aaron/ in any order
and press Start:
Aaron_Calib_Gridruns first (CalibrateStereo) -> a Camera Calibration next to the take.Aaron_Identity_DNAruns second (Identity Create): depth with that calibration -> neutral track -> conform -> AutoRig ->MHID_Aaron.Aaron_Take01..Nrun last (Stereo): preflight links the calibration andMHID_Aaron, and each take produces a Performance + AnimSequence.- Takes queued before their prerequisites simply wait as a blocked status and resume automatically once the parent completes.
Stereo-specific options
Depth and Other takes
A single camera that recorded its own depth solves down the same branch as Stereo, minus the depth generation stage: the take's depth is consumed as-is. The two types differ only in where the calibration comes from.
MHID_<Actor>, exactly as Stereo does. An identity take from a depth camera queues as an Identity Create job on the same name tokens (identity/dna); grid names are ignored for these takes. Calibration & Identity jobs
Stereo Calibration
Right-click a checkerboard take and choose Generate Stereo Calibration (Checkerboard
Take), or let name tokens (grid/calib) classify it. It drives
Epic's MetaHuman Calibration Processing plugin (UE 5.7+) and produces a
CC_<TakeName> asset linked to the Capture Data, plus an optional OpenCV
calib.json on disk. The board is measured in squares, not inner
corners (Epic's shipped board is 11 x 16 at 0.75 cm). The board pattern is detected and sharpness
tuned automatically unless Override default board is on. The board override lives
under Global Settings -> Camera Calibration and Depth,
the quality gates under Advanced -> Calibration Quality Gates.
Identity Create
Right-click a stereo identity take and choose Create MetaHuman Identity (Stereo),
or let identity/dna tokens classify it. It generates depth, tracks the
neutral frame, conforms the template mesh, runs Epic's cloud AutoRig, and prepares the identity
for performance (MHID_<Actor>). A finished identity is reused across the
actor's takes — delete the asset to force a rebuild.
Discovery and blocked states
Discovery is scoped to the actor's folders, which is why keeping a shoot's takes under one actor folder matters:
- Calibration lookup: already linked on the Capture Data -> capture parent folder -> take folder -> sibling take folders -> one level higher, never past
/Game. - Identity lookup: capture parent folder -> actor folder, preferring
MHID_<Actor>. - Rejected calibrations (set aside for poor quality) are invisible to every lookup until you accept or re-solve them.